Description
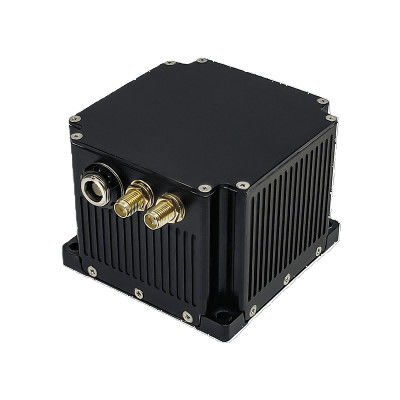
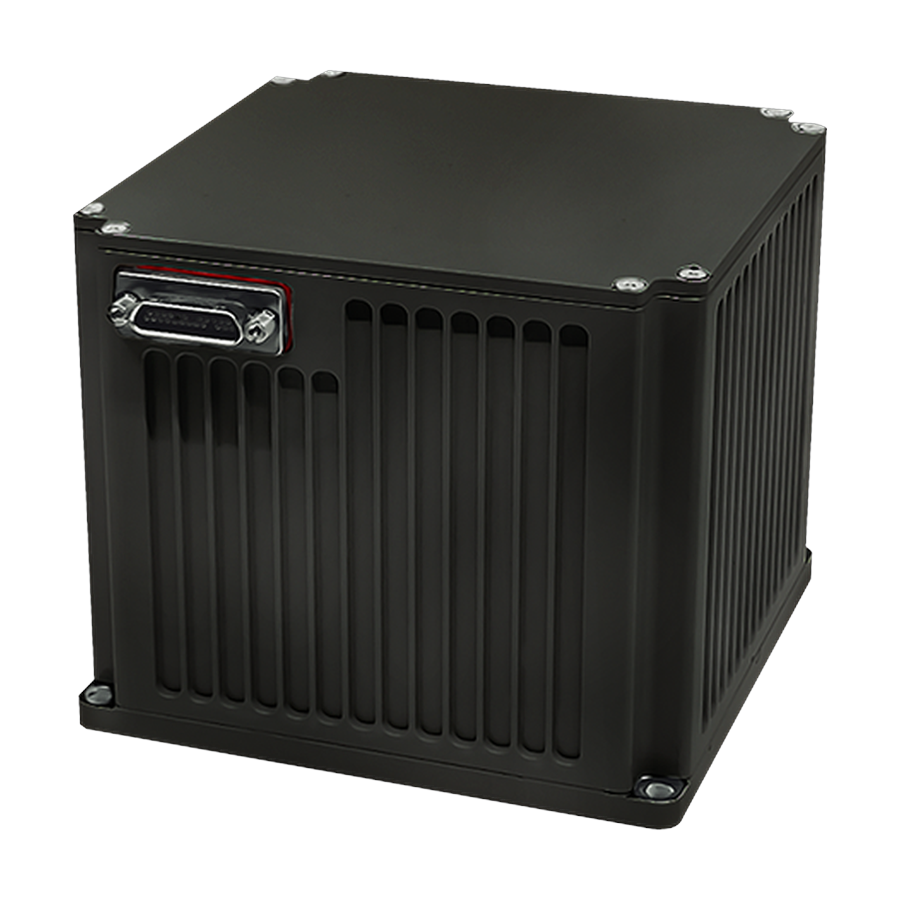
A airborne optical-gyro inertial navigation system (INS) (gyro bias repeatability ≤500μg) with fast startup, RS-422/Ethernet output and extended-temperature operation, suited to demanding navigation and stabilization applications.
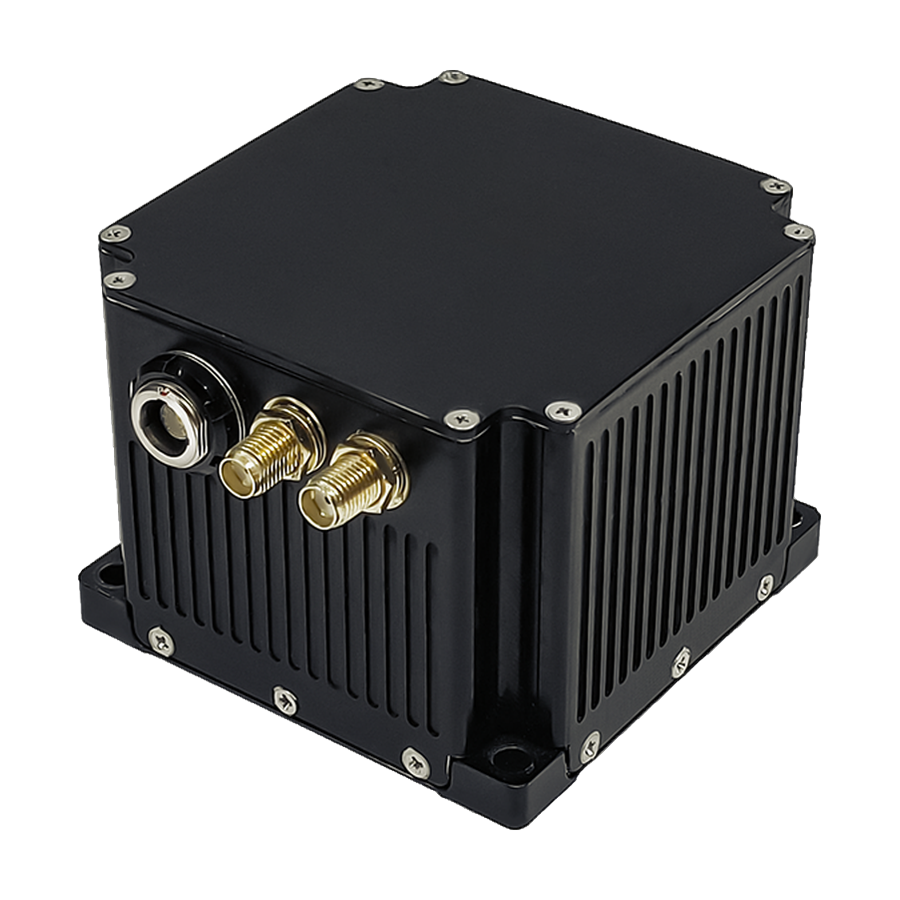
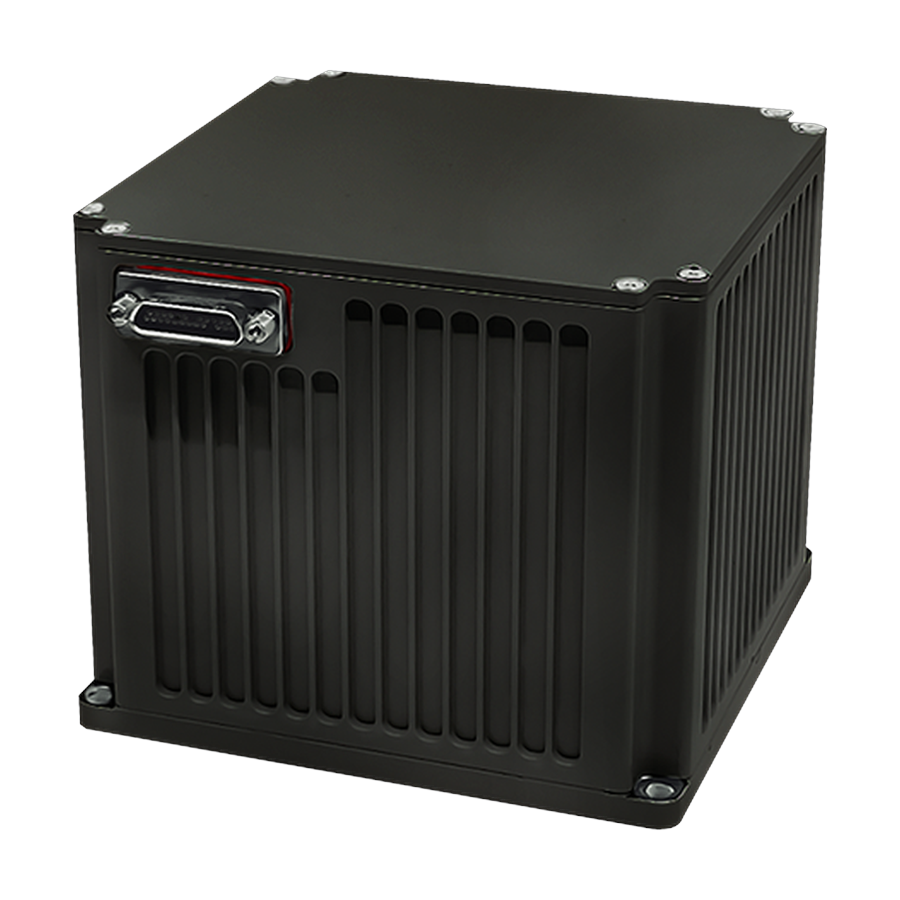
The Merak-A01(40S) Airborne Optical Gyro Inertial Navigation System (INS-A) is an airborne optical-gyro inertial navigation system (INS-A) from the Merak series. It integrates fiber optic gyroscopes (or, for the Dubhe-A1 high-end model, laser gyroscope technology) with quartz flexible accelerometers in a strapdown architecture and supports both ground-vibration-based and in-air alignment. The unit delivers a dynamic range of at least ±400°/s with excellent bias stability and low angular random walk. Key performance figures include Accelerometer Bias Repeatability (monthly, 1σ) ≤500μg; Accelerometer Scale Factor Accuracy (monthly, 1σ) ≤500ppm; Gyro Bias Repeatability (1σ) ≤0.15°/hr; Gyro Scale Factor Accuracy (1σ) ≤300ppm; Gyro Accuracy (10 s, 1σ) ≤0.3°/hr; Angular Random Walk (1σ) ≤0.05°/√hr. A companion “Deep Pilot” variant (SD-GH01) with the same specifications is also available. Electrical interfacing is provided through high-speed serial or Ethernet links with fast startup, and the unit operates over an extended industrial temperature range with high MTBF for long-endurance missions. Typical applications include fixed-wing UAVs, rotary-wing UAVs and special aerial platforms that require high-accuracy navigation, guidance and attitude reference. All specifications below are taken directly from the manufacturer’s 2026 catalog and datasheet.
Key specifications: Accelerometer Bias Repeatability (monthly, 1σ): ≤500μg; Accelerometer Scale Factor Accuracy (monthly, 1σ): ≤500ppm; Gyro Bias Repeatability (1σ): ≤0.15°/hr; Gyro Scale Factor Accuracy (1σ): ≤300ppm; Gyro Accuracy (10 s, 1σ): ≤0.3°/hr; Angular Random Walk (1σ): ≤0.05°/√hr.
Specifications
| Parameter | Value | Unit |
|---|---|---|
| Accelerometer Bias Repeatability (monthly, 1σ) | ≤500μg | |
| Accelerometer Scale Factor Accuracy (monthly, 1σ) | ≤500ppm | |
| Gyro Bias Repeatability (1σ) | ≤0.15°/hr | |
| Gyro Scale Factor Accuracy (1σ) | ≤300ppm | |
| Gyro Accuracy (10 s, 1σ) | ≤0.3°/hr | |
| Angular Random Walk (1σ) | ≤0.05°/√hr | |
| Position Accuracy (Pure Inertial) | 20m/60s(Ref.),500m/300s(Ref.),CEP | |
| Position Accuracy (INS/GNSS-aided) | better than satellite accuracy | |
| speed accuracy | pure inertia | —— |
| Angular Rate Range | ≥±400°/sec | |
| Angular Acceleration | 100000°/s² | |
| Acceleration Range | ≥40g | |
| Attitude | Any Orientation | |
| Input/Output Interface | 2 RS422 serial ports | |
| Alignment Time | ≤5min | |
| Heading Accuracy (Pure Inertial) | ≤1.5°secL+0.3°/h,RMS | |
| Heading Accuracy (INS/GNSS-aided) | ≤0.5°,RMS | |
| Pitch & Roll Accuracy (Pure Inertial) | ≤0.15°,RMS | |
| Pitch & Roll Accuracy (INS/GNSS-aided) | ≤0.1°,RMS | |
| Power Consumption | ≤10W | |
| Dimensions (L×W×H, mm) | 70×70×53 | |
| Weight | ≤500g | |
| Operating Temperature | -40°C~60°C | |
| Shock | 15g, Half-sine wave 11ms | |
| Input Voltage | DC24V(±25%) | |
| Cooling | Conduction to mounting plate | |
| Vibration | 20~2000Hz,6.06g | |
| MTBF | ≥20000 hours |
All specifications are taken from the manufacturer’s current datasheet.
Reviews
There are no reviews yet.